We profile feature extraction and matching to reduce latency while retaining drift stability.
cv::Ptr<cv::ORB> orb = cv::ORB::create(1200, 1.2f, 8);
orb->detectAndCompute(frame, cv::noArray(), kpts, desc);
x_t = f(x_{t-1}, u_t) + w_tAug 16, 2026 · 1 min read
A practical guide for deploying lightweight visual odometry on constrained onboard compute.
We profile feature extraction and matching to reduce latency while retaining drift stability.
cv::Ptr<cv::ORB> orb = cv::ORB::create(1200, 1.2f, 8);
orb->detectAndCompute(frame, cv::noArray(), kpts, desc);x_t = f(x_{t-1}, u_t) + w_t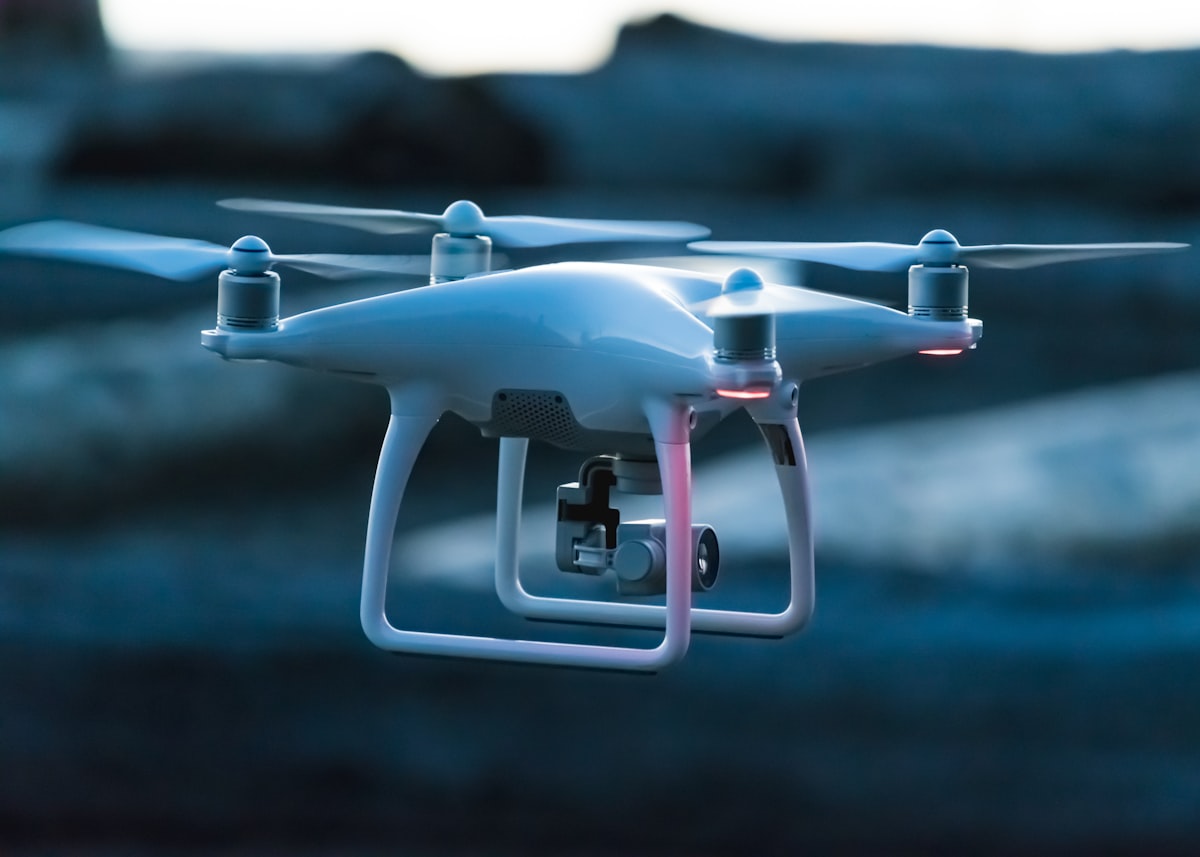
Automated waypoint generation and defect tagging for industrial assets.
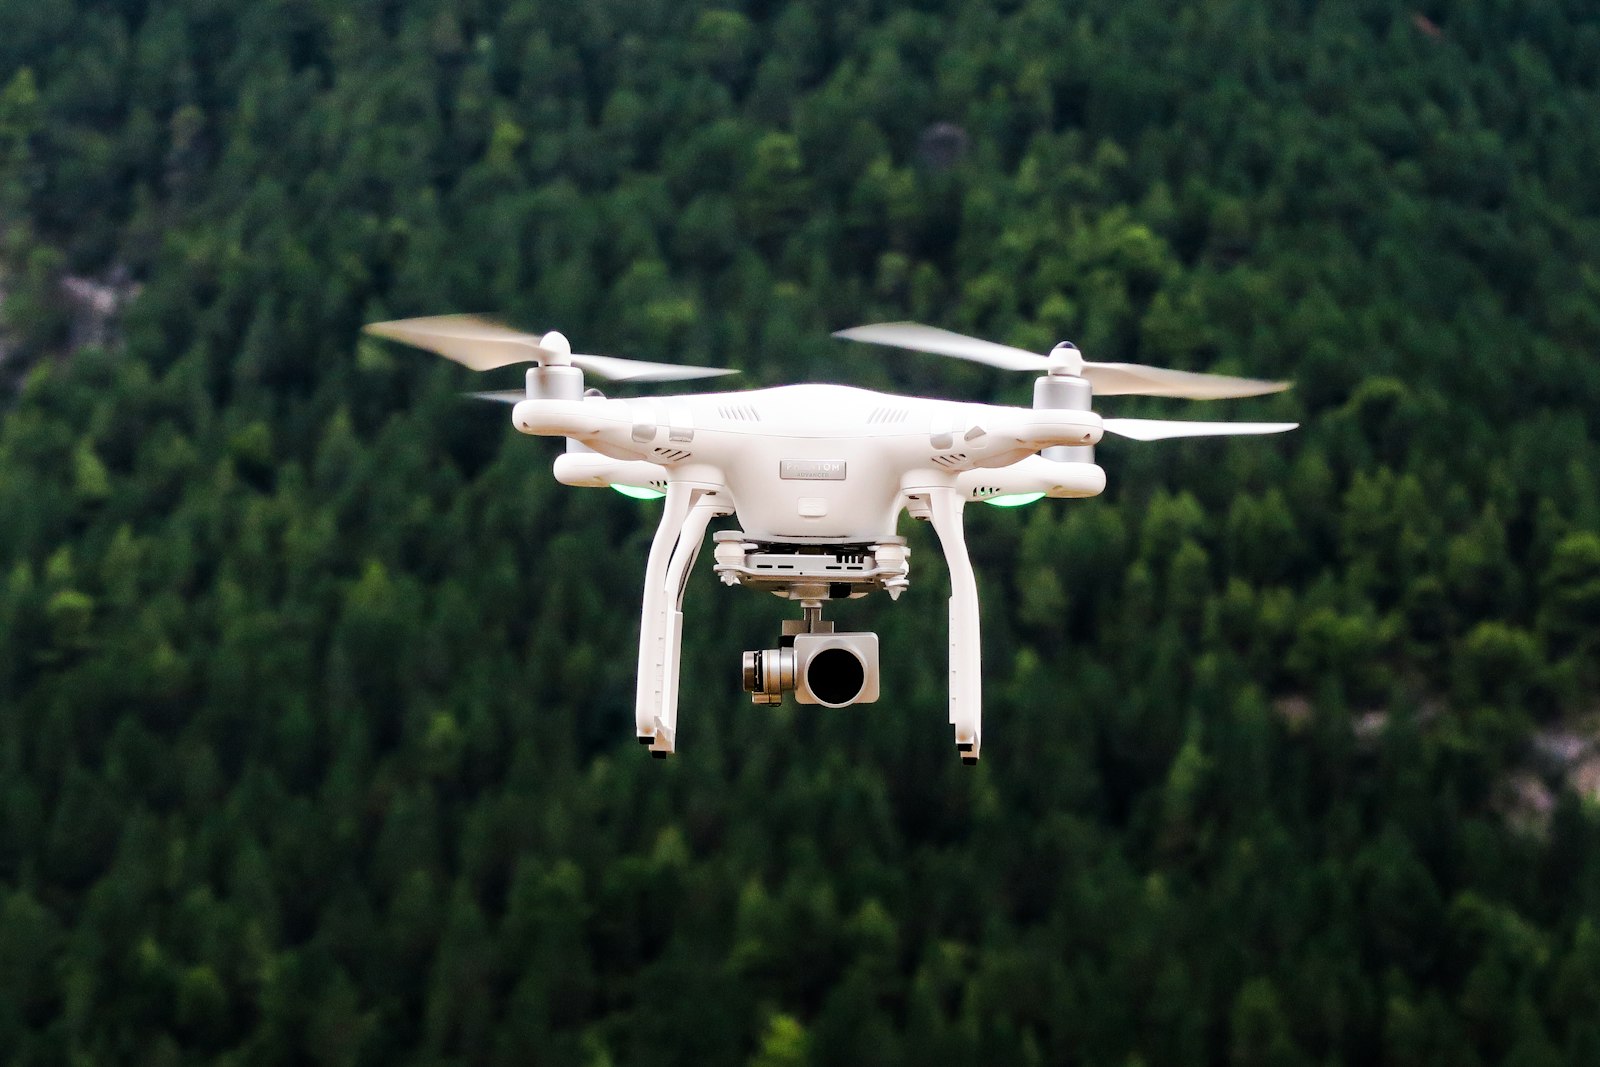
Visual-inertial odometry and LiDAR fusion for stable autonomous flight indoors.
A robust approach to mission waypoint optimization while preserving geofence and battery constraints.